RobotX: a racquetball launcher for a 16-foot autonomous boat
Led the mechanical work on a projectile launcher for Team Inspiration's autonomous surface vessel, with PID flywheel control and a fitted projectile model good to 10 meters.
Visit project ↗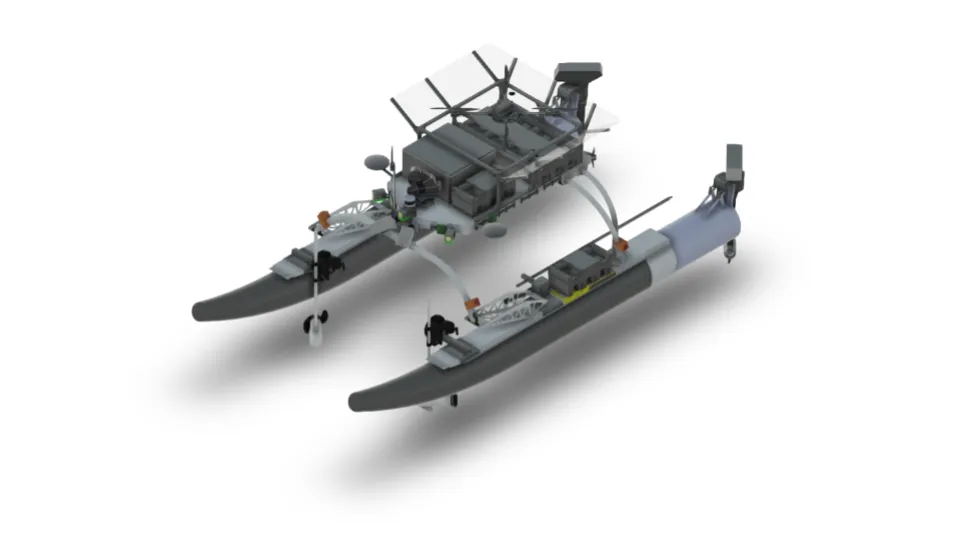
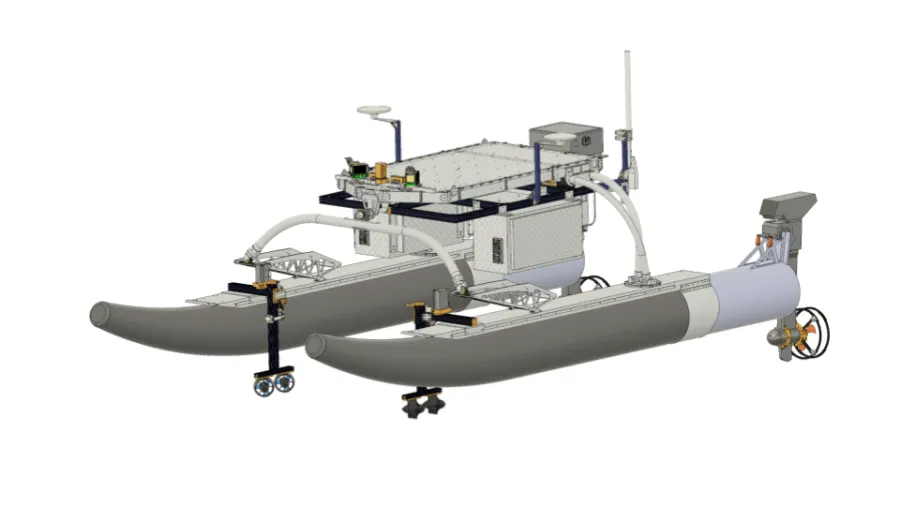
RobotX is RoboNation’s maritime competition: a 16-foot WAM-V catamaran has to navigate a course, read signals, and complete tasks fully autonomously. One of those tasks is delivering racquetballs into targets from the moving boat. I led the mechanical side of that launcher with UC San Diego students and faculty on Team Inspiration / Triton-AI.
What I built
- Launcher mechanism. Designed and iterated the launcher hardware in CAD and built it for the vessel’s payload tray.
- Flywheel control. Implemented a PID controller to hold the flywheel at a target speed, so launch velocity stayed consistent shot to shot as the battery sagged and the motor warmed up.
- Projectile model. Ran launch tests, fit a projectile model to the measured distances, and used it to solve for the launch speed and angle needed for targets up to 10 meters away.
- Field work. Helped debug the system during integration and on-water tests.
The boat itself, Crusader, is part of a three-vehicle system (surface, air, and underwater) that the team is fielding for RobotX 2026. The team’s 2024 entry placed 4th overall and 3rd in design documentation.
Renders: Team Inspiration. Swap in your own launcher photos when you have them.