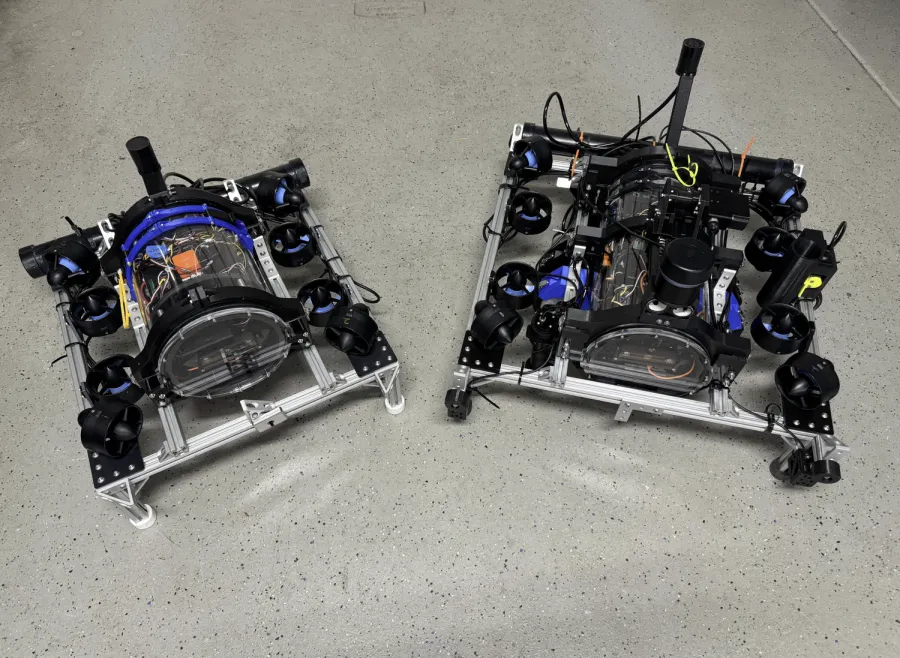
RoboSub: monocular vision and a marker dropper for an autonomous sub
A single-camera pipeline that estimates distance and bearing to underwater targets, plus a CAD-designed marker dropper with YOLO targeting, for Team Inspiration's RoboSub vehicle.
Visit project ↗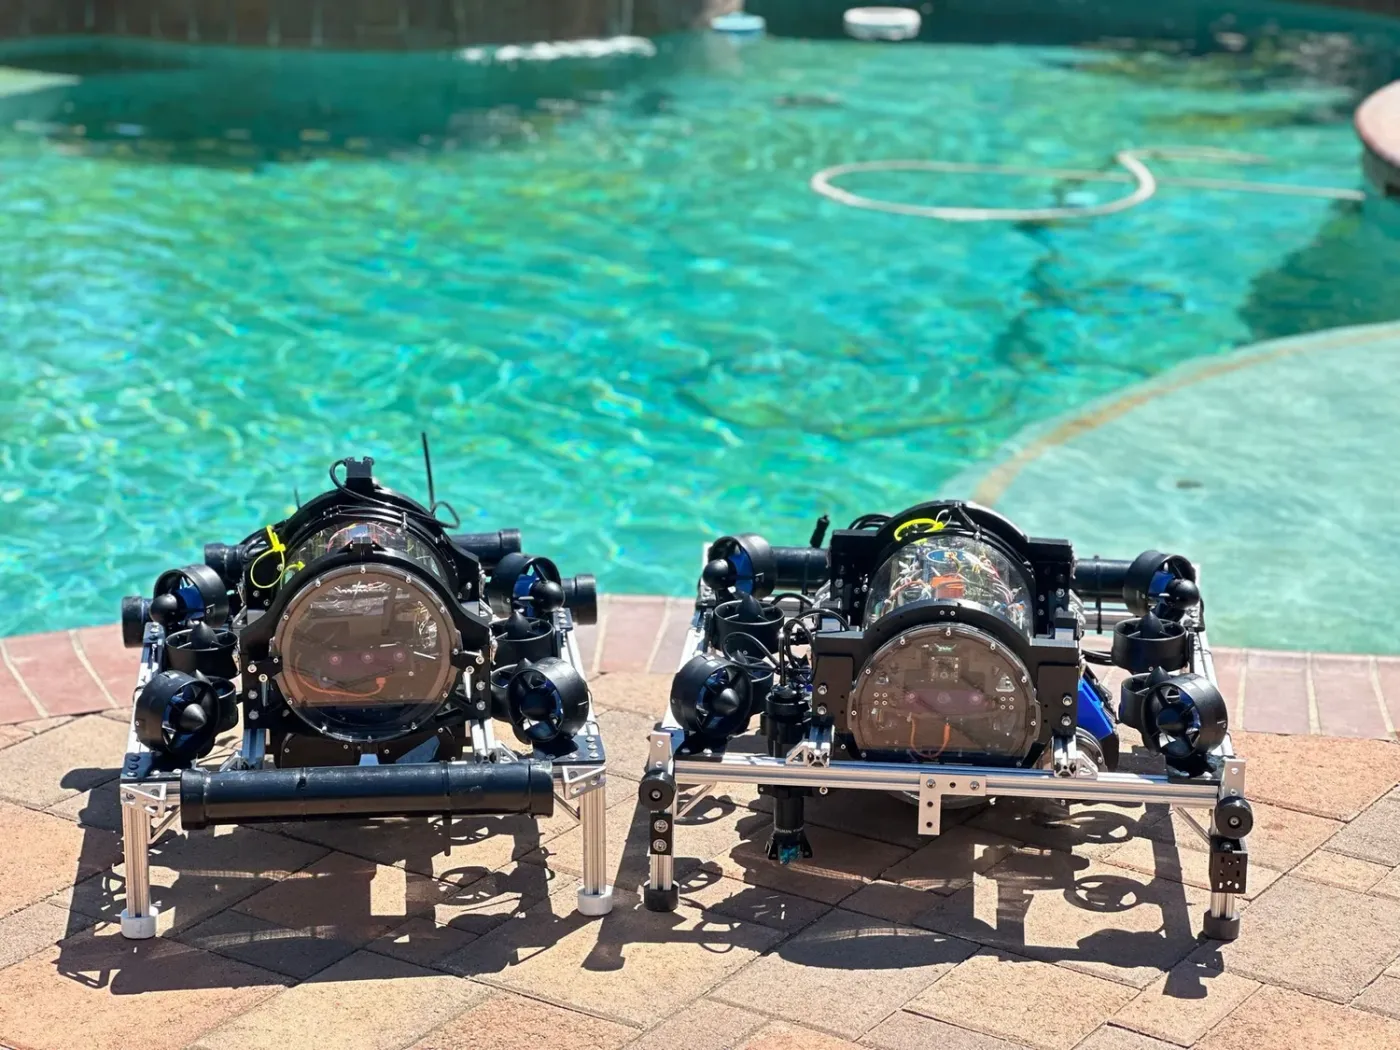
RoboSub is the underwater sibling of RobotX: an autonomous submarine has to find gates, buoys, and bins in a pool with no GPS and poor visibility. I joined Team Inspiration’s RoboSub effort in 2023 on the mechanical team and later moved into perception work with the UC San Diego students on the team.
Monocular distance and bearing
Stereo cameras are expensive and finicky underwater, so I built a pipeline that works from a single camera. Given a detected target’s pixel coordinates and its known physical size, the pipeline uses the camera’s intrinsics and some trigonometry to estimate how far away the target is and at what bearing. That gives the navigation stack a usable position estimate without a second camera or a sonar.
Marker dropper
One task asks the sub to drop markers into a bin of the correct color. I designed the dropper in CAD and paired it with a YOLO detector that locates the bin, so the sub can line up and release at the right moment. I also helped integrate the dropper with navigation and ran pool tests.
The team placed 5th worldwide at RoboSub 2024, 13th in 2025, and 9th in 2026.
Photos: Team Inspiration.